Skip to content
Inquiries and live demos are open now. Online payment and public price list: coming soon.Request a live demo

AGIBOT · Humanoid robots

G2

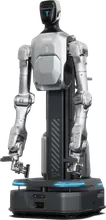
Industrial humanoid on a four wheel omnidirectional chassis, with two force controlled arms of seven degrees of freedom each for precision assembly. Built from automotive grade components, with IP42 protection.

Request a live demo
Slovenia and Croatia onlyPrice on request
Height
122.5 to 179.5cm
Weight
185kg
Degrees of freedom
25
Payload
10kg
G2

Overview

About G2

Uses

  • 01Precision assembly with force control
  • 02Logistics
  • 03Reception and guiding in exhibition spaces
  • 04Inspections
  • 05Education and research
  • 06Exhibitions and performances

Industries

Drive

Four wheel omnidirectional chassis

Availability

SloveniaCroatia

G2 is a wheeled humanoid robot built to industrial standards for factories, retail, entertainment and research. Two force controlled arms with seven axes and torque sensing in every joint allow work with sub-millimetre precision, such as finding holes, inserting parts and aligning surfaces. A three axis waist and folding legs let it reach low and high like a person, so it works without modification in environments designed for people. A chassis with four steered wheels moves in all directions, including sideways, which shortens turning time. Three fisheye cameras, two LiDARs and eight ultrasonic sensors provide 360 degree perception for active safety, and the arms respond to contact for passive safety. A microphone array, a face display and human-like gestures support conversation with several people, gaze tracking and roles as receptionist or guide, and it can be sent by voice to saved points on the map. Two hot swappable batteries and an optional charging station allow continuous operation, and it also supports low latency teleoperation (one operator for several robots), data collection kits and development through an SDK. Typical uses: logistics, precision assembly, guiding in exhibition spaces, reception, inspections, education and research, exhibitions and performances.
What it can do

Capabilities.

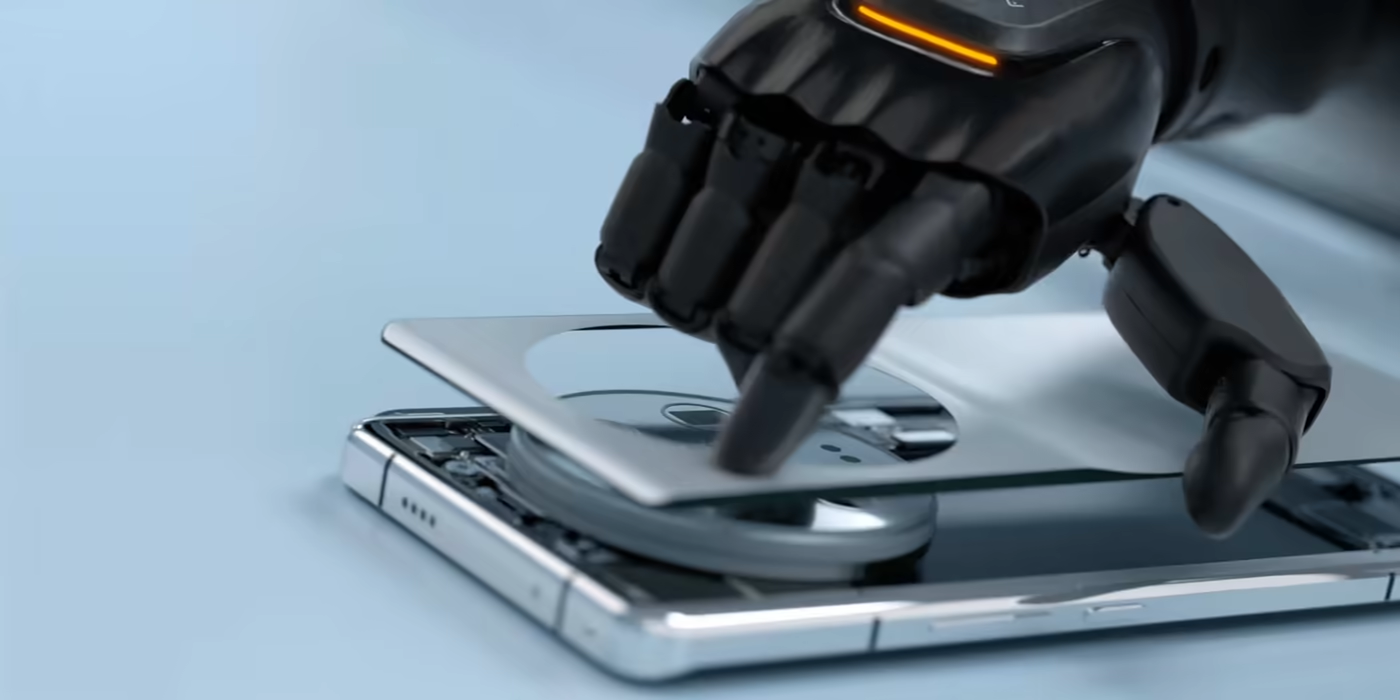
Close up of an AGIBOT G2 hand inserting a part into an open smartphone
01

Force control in every arm joint

Each arm has seven degrees of freedom, a rated payload of 5 kg and a torque sensor in every joint. With ±0.1 mm repeatability, force guided hole finding, insertion and loading reach sub-millimetre precision. A gripper or optional dexterous hand mounts on the end of each arm.

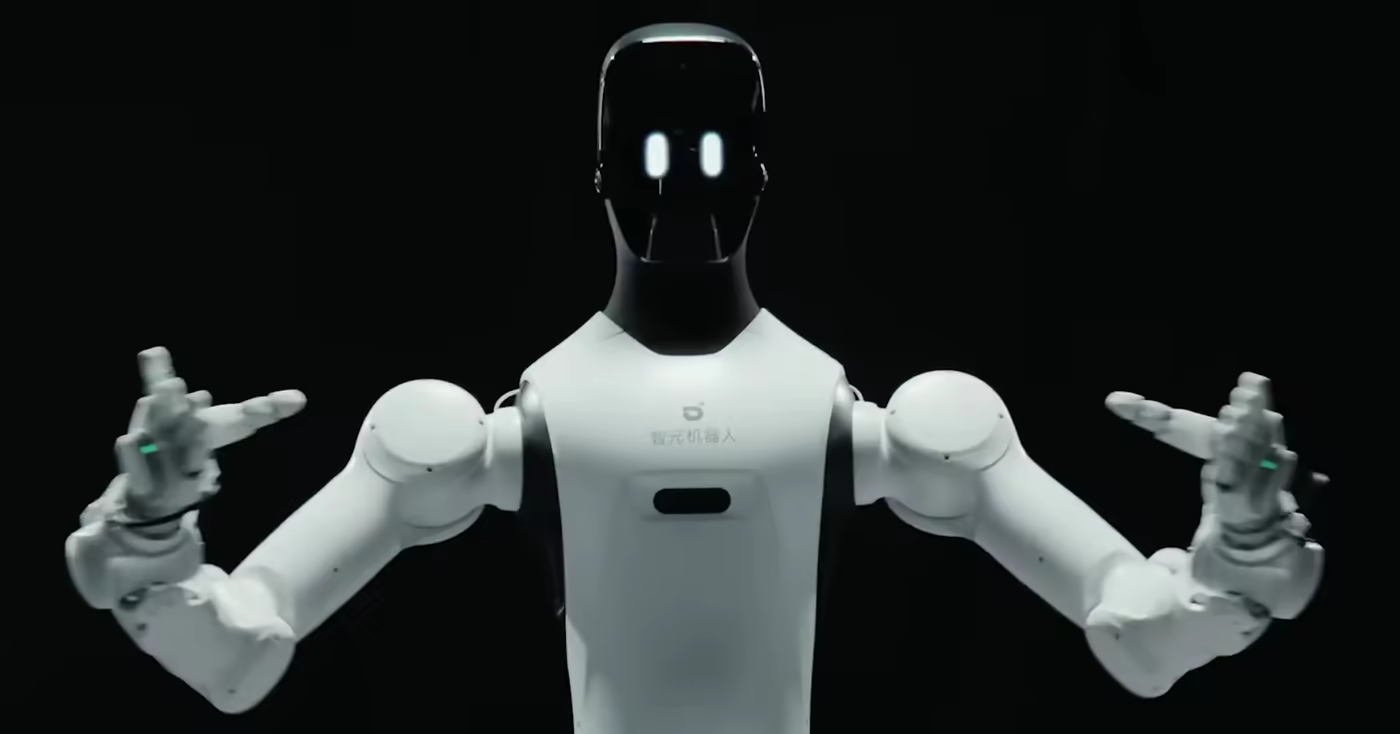
Upper body of the AGIBOT G2 robot with arms spread wide on a black background
02

Works from the floor up to 2.3 m

The torso has five degrees of freedom: the waist rotates and tilts forwards and sideways, and the legs fold to lower or raise the body. In the O10 version the vertical workspace spans 0 to 2.3 m, with a 2.3 m arm span.

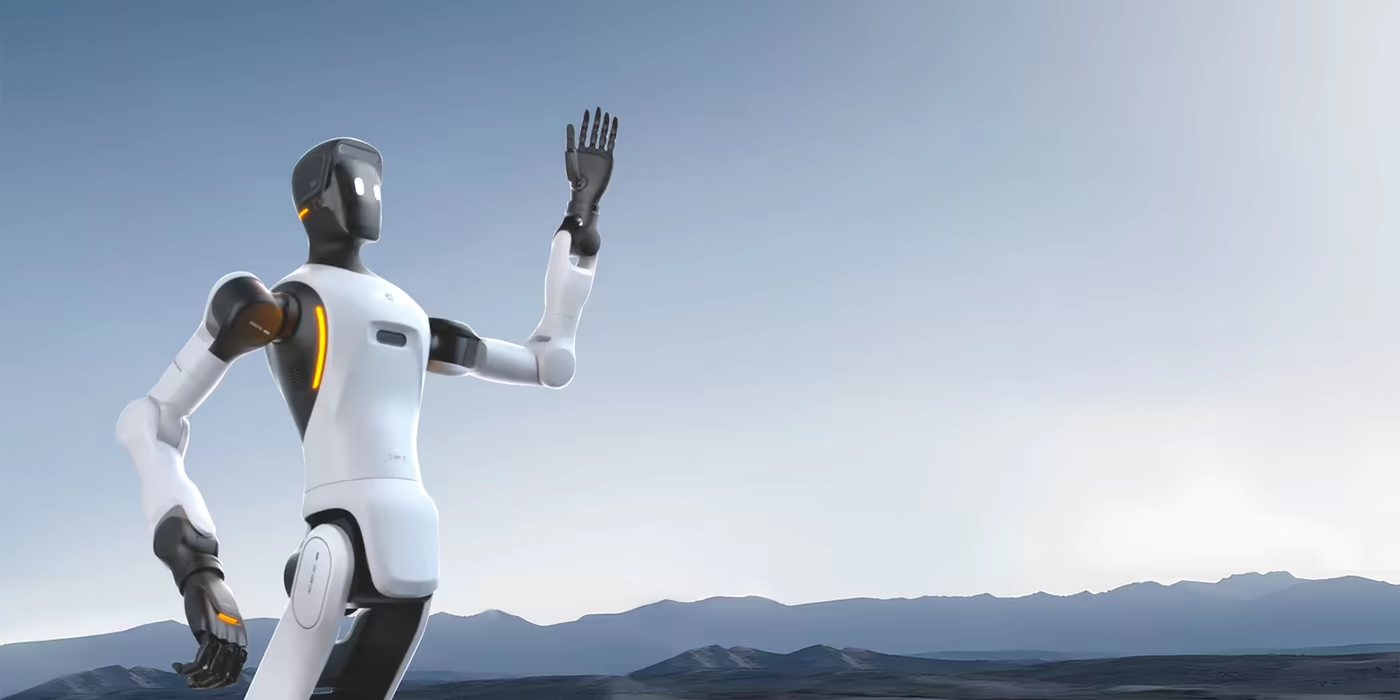
AGIBOT G2 humanoid robot waving in front of a mountain landscape
03

Expressions, gaze and conversation

A 6.3 inch face display shows expressive animations. Gaze tracking and conversation with several people at once let G2 work at a reception or in a showroom, not only on the production line.

Turns on the spot and drives sideways

Four steered wheels drive forwards and backwards, turn the robot on the spot and move it sideways in any direction at up to 1.5 m/s. It navigates aisles from 850 mm wide. Two hot swappable batteries with 1,652 Wh in total last about four hours, and with the optional charging station G2 returns to charge by itself.

Assembly on a real part

In a manufacturer clip, G2 uses two grippers to insert a memory module into a motherboard. Finding the slot and inserting the part with force control is the task its arms are designed for.

Cameras in the head and wrists

RGB-D cameras in the head and wrists recognise and locate the objects the arms work with. Three fisheye cameras give a 360° view, and two LiDARs and eight ultrasonic sensors around the chassis handle navigation and obstacle avoidance.

G2 · Technical data

Specifications.

Manufacturer specifications

Key specifications

Height
1,225 to 1,795 mm
Weight
185 kg
Degrees of freedom, without grippers
25
Rated payload, both arms
10 kg (5 kg per arm)
Arm repeatability
±0.1 mm
Vertical workspace (O10)
0 to 2.3 m
Max. speed
1.5 m/s
Battery
1,652 Wh, two hot swappable batteries
Runtime
Approx. 4 h
Compute
500 TOPS (INT8); higher compute version 2,070 TFLOPS (FP4)
Protection rating
IP42

Variants

StandardHigh compute

Notes on the data

  • Operating temperature: the table lists 0 to 45 ℃, the safety instructions 0 to 40 ℃.
  • Terminal interface languages: Chinese and English.

Full technical sheet

117 items
General10 items
Robot typeWheeled humanoid robot
Degrees of freedom (without end effector)25
Head degrees of freedom3
Arm degrees of freedom (per arm)7
Torso degrees of freedom5 (waist 3 degrees of freedom, legs 2 degrees of freedom with folding lift)
Protection rating (whole unit)IP42
Components100 % automotive grade components
Physical emergency stop buttonSupported
Emergency stop modesSoftware stop (triggered from the wireless terminal); hardware stop (button on the back cuts power to the actuators)
Terminal interface languagesChinese and English
Dimensions and weight7 items
Height1225 mm to 1795 mm
Width640 mm
Length760 mm
Weight185 kg
Vertical workspace (with O10)0 to 2.3 m
Arm span (with O10)2.3 m
Arm length696 mm
Range of motion15 items
Head rotation±70°
Head side tilt±20°
Head pitch±27°
Waist rotation±174°
Side tilt±24°
Waist bend-104° to 58°
Knee0° to 151°
Ankle-61° to 0°
Shoulder rotation±178°
Shoulder lift±120°
Upper arm±178°
Elbow-145° to 60°
Forearm±178°
Wrist lift±90°
Wrist deviation±60°
Arms and end effector12 items
Arm typeForce controlled arm, 7 degrees of freedom (x2)
Rated load, one arm5 kg
Rated load, both arms10 kg
Max. load, both arms15 kg
Positioning repeatability±0.1 mm
Absolute positioning accuracy±1 mm
Joint torque sensorsYes, in every arm joint
Force control resolution≤0.02 N.m
Force sensor sampling rate≥5 kHz
Arm endStandard robot arm flange
End effector connector (wrist)M8, 8 pins: 1x 24 V power, 2x RS485, 1x CAN-FD; not hot swappable
Dexterous handOptional (various dexterous hands and grippers)
Torso and chassis13 items
Torso designFolding lift
WaistPitch, rotation, lateral tilt
LegsFolding lift
Chassis type4 steered drive wheels
Max. speed1.5 m/s
Turning on the spotSupported
Sideways (crab) movementSupported, in any direction
Navigation accuracy, standard±5 cm, ±3°
Navigation accuracy, high±3 cm, ±2°
Max. obstacle height1.5 cm
Climbing ability≤5°
Min. passage width for navigation850 mm
Max. map area10,000 m²
Sensors8 items
Head stereo camera1 unit; camera1 and camera2 1920 (H) x 1536 (V); 60 fps; field of view 118° (H) x 92° (V)
Head fisheye cameras3 units; 1920 (H) x 1537 (V); 30 fps; field of view 215° (H) x 170° (V); 360° panoramic view
Head RGBD camera1 unit; RGB 1280 (H) x 800 (V), 60 fps, field of view 94° (H) x 68° (V); depth 1280 (H) x 800 (V), 30 fps, field of view 90° (H) x 65° (V)
Wrist RGBD cameras2 units; RGB 1920 (H) x 1080 (V), 25 fps, field of view 105° (H) x 85° (V); depth 640 (H) x 480 (V), 25 fps, field of view 90° (H) x 70° (V)
Chassis LiDAR2 units; min. detection distance 0.1 m; accuracy (1σ) ≤2 cm (at 10 m), ≤3 cm (at 0.2 m); field of view 360° (H), -7° to 52° (V); 200,000 points/s; 10 Hz
Chassis ultrasonic sensors8 units; accuracy 20 mm; detection angle 100°±10° (H), 60°±10° (V)
Chassis IMU, gyroscopeMeasuring range ±250 °/s; zero offset over the full temperature range 0.015 °/s (typical), 0.03 °/s (max.); zero stability 4 °/h (typical), 6 °/h (max.)
Chassis IMU, accelerometerMeasuring range ±8 g; zero offset over the full temperature range 1.5 mg (typical), 2 mg (max.); zero stability 0.07 mg (typical), 0.1 mg (max.)
Interaction8 items
Head microphones4 microphone array; sensitivity -32±3.5 dB; signal to noise ratio 70 dBA
Speech pickup rangeUp to 3 m
Head speaker1 unit; rated power 8 W, max. 10 W; impedance 4 Ω ± 15 %; resonant frequency 200±20 % Hz; sensitivity 83±3 dB; frequency response f₀ to 8 kHz
Interactive display size6.3 in (table); 6.36 in flexible display (manual text)
Interactive display brightness500 nits
Status light strips7 distributed light strips
Wireless terminal display11.5 in; 2000 (H) x 1200 (V)
Wake phrase (English)"Hi Genie"
Compute platform8 items
SpecificationStandardHigh compute
Compute500 TOPS (INT8)2,070 TFLOPS (FP4)
CPU cores24*A7814*Poseidon-AE
Memory64 GB128 GB
Storage2 TB NVMe SSD2 TB NVMe SSD
Interfaces and connectivity13 items
SpecificationStandardHigh compute
Internet (WAN) port1 Gb/s
LAN ports1 Gb/s and 10 Gb/s
Upper limb debug portYes, service staff only
USB Type-AUSB 3.0 speed (standard lower compute version only)On request
DP portYes, for connecting a monitorOn request
Debug serial portOn requestYes, service staff only
USB Type-CUSB 3.0 speed
4G/5G SIM card slotSupported
Wi-FiSupported
BluetoothSupported
4G/5GOptional
Teleoperation connection modesWithout video: direct cable or LAN (UDP); with video: WebRTC server on the LAN or WebRTC over the public network
Recommended bandwidth for teleoperation with video20 Mb/s per robot
Battery and power10 items
Number of batteries2, hot swappable
Total battery capacity1,652 Wh (34 Ah)
Total runtimeApprox. 4 h
Rated voltage48 V
Rated current8.3 A
Rated powerApprox. 400 W
Charger modelUY900L-W547150
Charger output54.75 V, 15 A, max. power 821.25 W
Charger input100 V to 240 V, 47 to 63 Hz
Automatic chargingSupported with the optional charging station
Environment7 items
Operating temperature0 ℃ to 45 ℃ (table); the safety instructions state 0 ℃ to 40 ℃
Storage temperature-20 ℃ to 60 ℃
Operating humidity≤90 %
UseIndoors, on flat dry floors
Driving slope (safety instructions)≤5 %
Recommended clear space for voice interactionAt least 1 m radius around the robot
Battery maintenance in storageFully charge every 60 days; at least 60 % before switching off if the robot will not be used for more than a week
Package contents6 items
Robot body×1
Battery charger×1
Certificate of conformity×1
Warranty card×1
Packing list×1
Tool kit×1

G2 · Images

Gallery.

Buy and rent

Make it yours.

Price on request. This model is available in Slovenia and Croatia only.

Buy

Slovenia and Croatia only

Price on request. You receive a written offer with contract terms, prepared for your configuration, software and service.

Rent

Purchase only

Rental is offered in Slovenia for Walker S2 and Cruzr S2. This model cannot be rented: see it at a live demo or request an offer.

Live demo

Live demo if the model is available for viewing.

Coming soonOnline payment · Public price list

Inquiry

Inquiry for G2.

Tell us the task and your country. We will reply by email with the next steps.

What are you interested in?
Robots you are interested in
We use your data to prepare the demo or offer, and pass the inquiry to the delivery partner, who prepares the offer and supplies the robots.

Thank you. Your inquiry is in.

We will reply by email with the next steps: a live demo where possible, and a written offer.

Rental in Slovenia

UBTECH · Legged (bipedal)

Walker S2

Industrial humanoid that swaps its own battery

Height
176 cm
Weight
70 kg
DoF
52
Humanoid robotsDetails
Rental in Slovenia

UBTECH · Wheeled base

Cruzr S2

Wheeled humanoid for industrial work

Payload
15 kg
Speed
2 m/s
Humanoid robotsDetails

UBTECH · Legged (bipedal)

Walker C1

Service humanoid for reception and guided tours

Height
164 cm
Weight
55 kg
DoF
53
Humanoid robotsDetails
Slovenia and Croatia only

AGIBOT · Legged (bipedal)

A3 Ultra

Humanoid for long shifts

Height
174 cm
Weight
60 kg
DoF
51 to 71
Humanoid robotsDetails
Slovenia and Croatia only

AGIBOT · Legged (bipedal)

X2 Ultra

Compact humanoid for interacting with people

Height
131 cm
Weight
39 kg
DoF
30
Humanoid robotsDetails

UBTECH · Legged (bipedal)

Walker Tienkung

Humanoid platform for research and teaching

Height
173 cm
Weight
75 kg
DoF
42
Humanoid robotsDetails

Your inquiry

Your inquiry list is empty.

Add robots in the store, then send one inquiry for all of them.

Open the store

Price on request. No online payment. Nothing is ordered or paid here. We reply with a written offer.

Send inquiry Request a live demo