Skip to content
Inquiries and live demos are open now. Online payment and public price list: coming soon.Request a live demo

UBTECH · Humanoid robots

Walker Tienkung

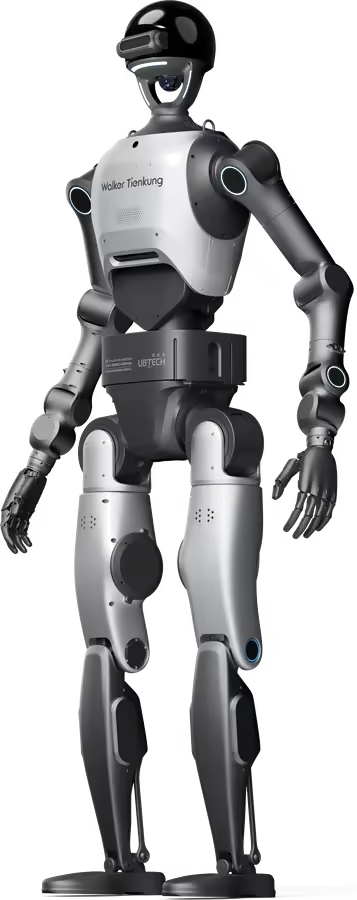
Full-size humanoid for research and teaching, with five finger dexterous hands and open interfaces on every joint and sensor.

Request a live demo
Sale: EU, on inquiryPrice on request
Height
173cm
Weight
75kg
Degrees of freedom
42
Runtime
3.5h
Walker Tienkung

Overview

About Walker Tienkung

Uses

  • 01Motion control research
  • 02Multimodal interaction with vision and language models
  • 03Manipulation with both dexterous hands
  • 04Teaching and education
  • 05Teleoperation and data capture for embodied AI

Industries

Drive

Legged (bipedal)

Availability

SloveniaCroatiaSerbiaBosnia and HerzegovinaNorth Macedonia

Walker Tienkung Embodied Intelligence is a full-size bipedal humanoid robot for research, education and further development. It walks with adaptive gait control, maintains balance in real time and responds to pushes and other external disturbances. According to the manufacturer, the series can stand, walk and run, and walks stably on slopes and sand. All joints and sensors have open interfaces with guides and sample code, so teams can run teleoperation, capture data and develop their own software. The manufacturer provides URDF models, open learning frameworks including AMP style reinforcement learning, and tools for learning manipulation strategies. Open embodied AI datasets with multi view RGB-D recordings, robot state, end effector state and natural language task descriptions are being released step by step. Typical uses are motion control research, multimodal interaction with vision and language models, and manipulation with both dexterous hands.

Manufacturer footage

Straight from the manufacturer.

Walker Tienkung outdoors: walking on a road, waving in a park and by the sea
Two Walker Tienkung robots in a bright laboratory passing a tablet

Images and video: manufacturer materials (UBTECH).

In motion

See it move.

The dexterous hand moves blocks into a basket

What it can do

Capabilities.

Walker Tienkung humanoid robot, angled view from the front left
01

Built for research and teaching

Walker Tienkung is a fully electric full-size humanoid designed for scientific research and education. In its most complete version it has 42 degrees of freedom: 3 in the head, 7 in each arm, 6 in each hand, 1 in the waist and 6 in each leg.
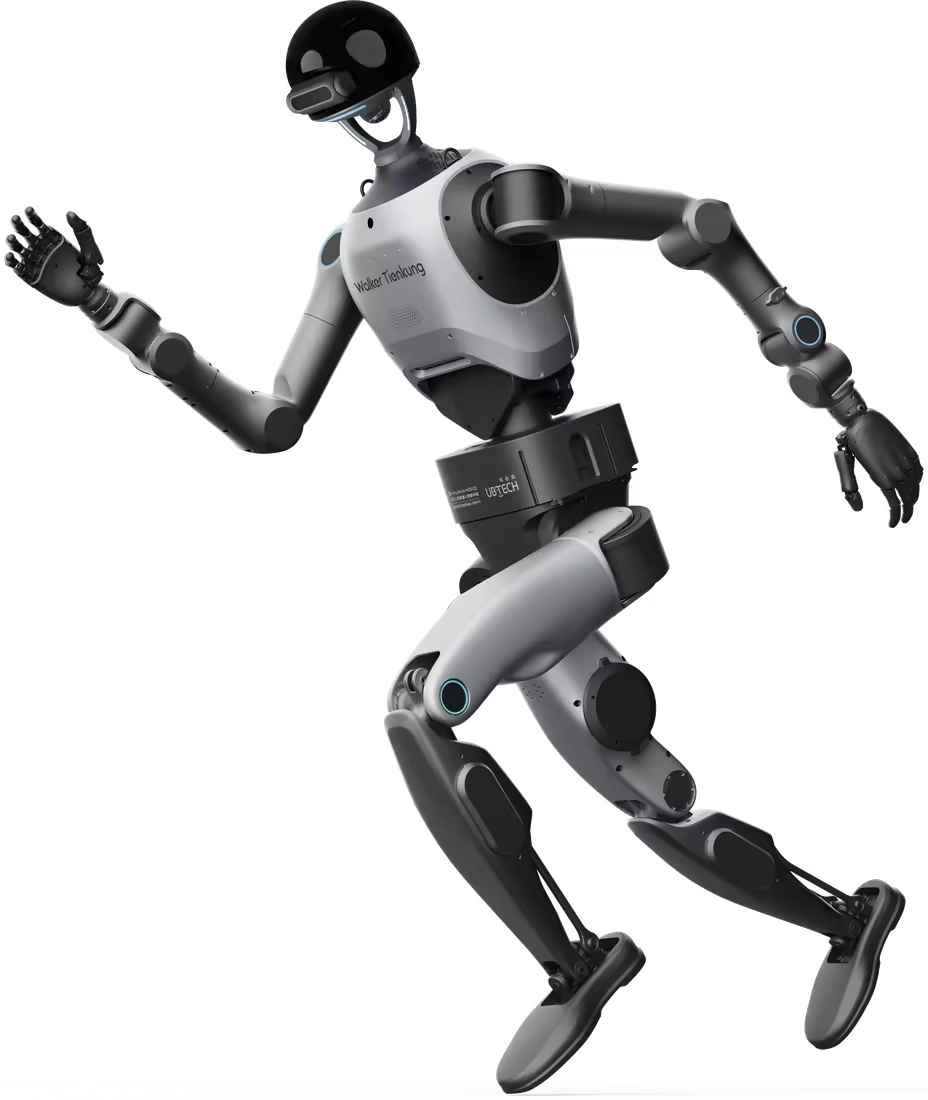
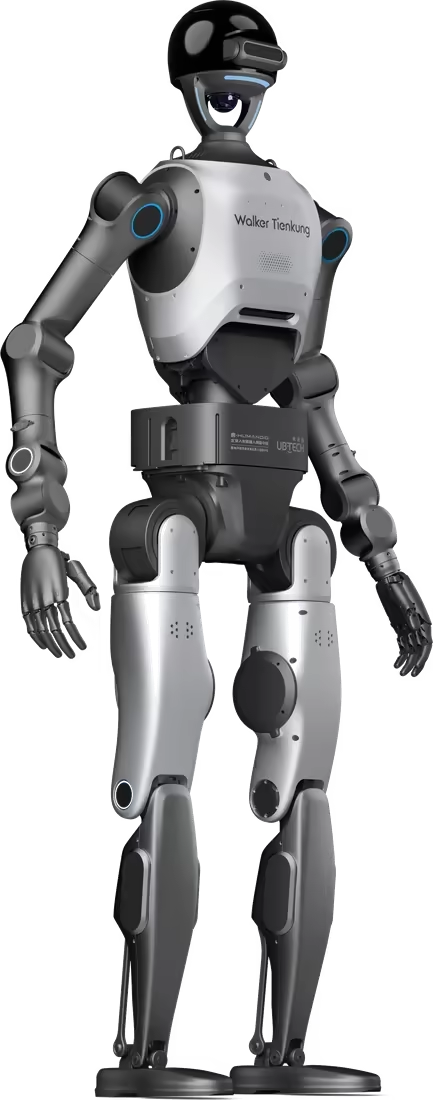
Walker Tienkung humanoid robot running, side view
02

Walks and runs on uneven terrain

The robot stands, walks and runs, and stays stable on slopes and sand. Its gait is based on motion control learned through reinforcement learning, and the manufacturer describes how to train and deploy your own gaits.

Walker Tienkung humanoid robot standing upright, angled front view
03

Keeps its balance when pushed

Powered joints and a precise inertial measurement unit let it respond to external disturbances in real time and keep its posture. Dynamic balance is one of the main features the manufacturer lists for the platform.

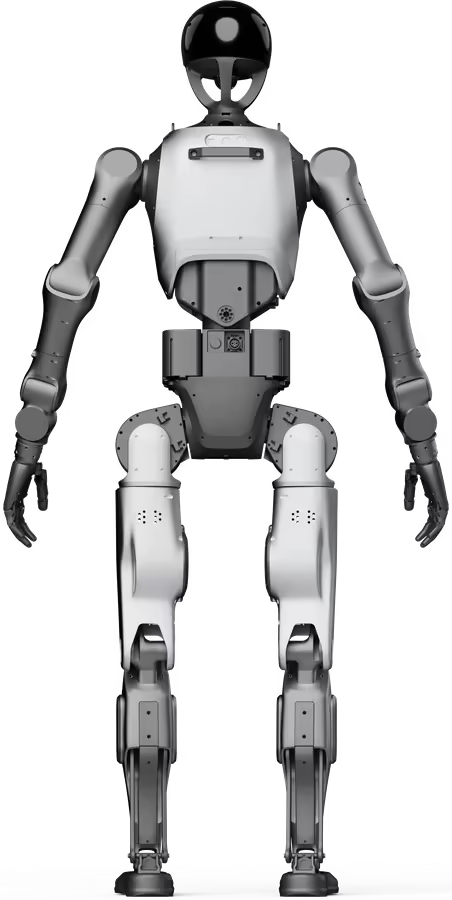
Walker Tienkung humanoid robot from behind, with back and waist modules visible
04

Open interfaces on every joint and sensor

All joints and sensors have open interfaces for teleoperation, data capture and your own development. The manufacturer provides development material with guides and code samples, accurate URDF models and open source learning frameworks.

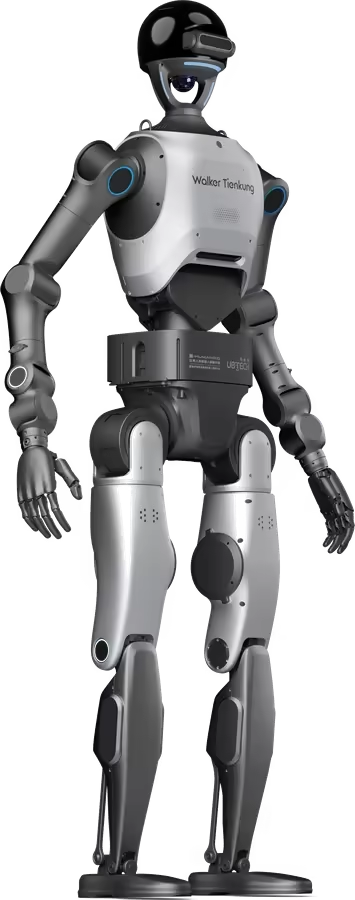
Walker Tienkung humanoid robot, angled view from the front right
05

Two batteries, more than 3.5 hours

A dual battery system with fast swapping gives more than 3.5 hours of continuous operation. With its voice module and a large language model it accepts spoken commands, and onboard computing reaches up to 550 TOPS.

Five finger dexterous hands

In the Embodied Intelligence version, five finger dexterous hands are standard equipment, and a six-axis force sensor can be mounted on each wrist. The manufacturer publishes an imitation learning grasping example for them. The film shows a hand picking up blocks and placing them in a basket.

Walker Tienkung · Technical data

Specifications.

Manufacturer specifications

Key specifications

Manufacturer
UBTECH
Degrees of freedom
Up to 42
Height
1730 ± 10 mm
Net weight
75 kg (Embodied Intelligence version)
Arm span
600 mm
Hands
Five fingers, 6 degrees of freedom each
Runtime
More than 3.5 h
Charging time
Less than 4 h
Battery
Lithium ion (NMC), 48 V, 30 Ah + 3 Ah
Development compute
Up to 550 TOPS (2 × 275 TOPS)
Cameras
RGB-D in the head, waist and back
Software
Ubuntu 22.04 LTS, ROS
Connectivity
Wi-Fi 6, Ethernet, Bluetooth
Max. speed
10 km/h*

Variants

Embodied Intelligence (TK2301)

Notes on the data

  • * Preliminary value, not yet confirmed
  • Speed: the datasheet lists 7 km/h; the summary lists a max. of 10 km/h (not yet confirmed).
  • Datasheet vs product page: height 1730 ± 10 mm vs 172 cm, weight 75 kg vs approx. 73 kg, runtime more than 3.5 h vs 3 h.

Full technical sheet

59 items
General5 items
SpecificationEmbodied Intelligence (TK2301)
ModelWalker Tienkung Embodied Intelligence (TK2301)
ColourMetallic grey + black
MaterialsAluminium alloy + engineering plastic
System opennessOpen interfaces for whole body motor control, sensors and API
OTA updatesSupported
Dimensions and weight5 items
SpecificationEmbodied Intelligence (TK2301)
Height1730 ± 10 mm
Height (product page)172 cm
Arm span600 mm
Net weight75 kg
Total weight (product page)Approx. 73 kg
Degrees of freedom9 items
SpecificationEmbodied Intelligence (TK2301)
Total degrees of freedom42 integrated joints (head 3; arms 7 × 2; hands 6 × 2; waist 1; legs 6 × 2), each combining motor, reducer and encoder
Total degrees of freedom (product page)42
Head (neck) degrees of freedom3
ArmsArms with 7 degrees of freedom × 2
Degrees of freedom per arm7 (shoulder × 3 + elbow × 1 + wrist × 3)
Degrees of freedom per leg6 (hip × 3 + knee × 1 + ankle × 2)
Waist degrees of freedom1
HandsFive finger dexterous hand with 6 degrees of freedom × 2
Dexterous handsStandard equipment
Motion20 items
SpecificationEmbodied Intelligence (TK2301)
Movement speed7 km/h
Max. joint torque300 N.m
Joint gain range (all joints)Kp 0 to 2000, Kd 0 to 300
Head, side tilt (ID 1)-26° to +26°; 2.16 Nm/A; max. 64 rpm; rated 3 Nm; max. 9 Nm
Head, forward and backward tilt (ID 2)-25° to +25°; 2.16 Nm/A; max. 64 rpm; rated 3 Nm; max. 9 Nm
Head, rotation (ID 3)-90° to +90°; 2.16 Nm/A; max. 64 rpm; rated 3 Nm; max. 9 Nm
Waist, rotation (ID 31)-170° to +170°; 3.207 Nm/A; max. 88 rpm; rated 35 Nm; max. 91 Nm
Shoulder, pitch (ID 11 / 21)-170° to +170°; 3.207 Nm/A; max. 88 rpm; rated 35 Nm; max. 91 Nm
Shoulder, abduction (left ID 12 / right ID 22)Left -15° to +150°, right -150° to +15°; 3.37 Nm/A; max. 120 rpm; rated 20 Nm; max. 60 Nm
Shoulder, rotation (ID 13 / 23)-170° to +170°; 2.43 Nm/A; max. 73 rpm; rated 10 Nm; max. 30 Nm
Elbow, pitch (ID 14 / 24)-150° to +15°; 2.43 Nm/A; max. 73 rpm; rated 10 Nm; max. 30 Nm
Wrist, rotation (ID 15 / 25)-170° to +170°; 1.71 Nm/A; max. 146 rpm; rated 5 Nm; max. 15 Nm
Wrist, pitch (ID 16 / 26)-45° to +60°; 2.16 Nm/A; max. 72 rpm; rated 3 Nm; max. 9 Nm
Wrist, abduction (left ID 17 / right ID 27)Left -95° to +75°, right -75° to +95°; 2.16 Nm/A; max. 72 rpm; rated 3 Nm; max. 9 Nm
Hip, abduction (ID 51 / 61)-45° to +45°; 2.3 Nm/A; max. 125 rpm; max. 124 Nm
Hip, pitch (ID 52 / 62)-160° to +120°; 2 Nm/A; max. 125 rpm; max. 300 Nm
Hip, rotation (ID 53 / 63)-60° to +60°; 2.3 Nm/A; max. 125 rpm; max. 124 Nm
Knee, pitch (ID 54 / 64)0° to +137°; 2 Nm/A; max. 125 rpm; max. 300 Nm
Ankle, pitch (ID 55 / 65)-70° to +30°; 2.6 Nm/A; max. 128 rpm; max. 36 Nm
Ankle, abduction (ID 56 / 66)-30° to +30°; 2.6 Nm/A; max. 128 rpm; max. 36 Nm
Dexterous hand3 items
SpecificationEmbodied Intelligence (TK2301)
Little, ring, middle and index finger range+19° to +176.7°
Thumb flexion range-13° to +53.6°
Thumb rotation range+90° to +165°
Battery and power5 items
SpecificationEmbodied Intelligence (TK2301)
Main batteryTernary lithium; 30 Ah + 3 Ah; 48 V
Charging timeLess than 4 h
RuntimeMore than 3.5 h
Runtime (product page)3 h
Battery systemDual battery system with fast swap
Compute unit and sensors8 items
SpecificationEmbodied Intelligence (TK2301)
Motion control compute unitIntel x86 i7-1355U; 10 cores, 12 threads; up to 5 GHz; 16 GB RAM; 256 GB SSD
Development compute unitOrin AGX 64 × 2; 275 TOPS × 2
Perception compute unit (product page)NVIDIA Jetson AGX Orin × 2; 550 TOPS
Operating system and middlewareUbuntu 22.04.4 LTS; ROS
Middleware (product page)ROS2
Inertial measurement unit (IMU)High precision IMU
Force sensors6-axis force/torque sensor × 2
CamerasRGB-D on the head × 1, RGB-D on the waist × 1, RGB-D on the back × 1
Interaction1 item
Voice moduleLinear 4 microphone array; speaker × 1; sound card × 1; 720p RGB monocular camera × 1
Communication3 items
External communicationWi-Fi 6, Ethernet, Bluetooth
Internal communication busCAN/EtherCAT for the whole body; leg control ≥ 1 kHz; arm control 400 Hz (max.)
Max. control frequency (product page)1000 Hz

Walker Tienkung · Images

Gallery.

Buy and rent

Make it yours.

Price on request. Sales across the EU, on inquiry. Available in Slovenia, Croatia, Serbia, Bosnia and Herzegovina and North Macedonia. Other countries: on request.

Buy

Sale: EU, on inquiry

Price on request. You receive a written offer with contract terms, prepared for your configuration, software and service.

Rent

Purchase only

Rental is offered in Slovenia for Walker S2 and Cruzr S2. This model cannot be rented: see it at a live demo or request an offer.

Live demo

Live demo if the model is available for viewing.

Coming soonOnline payment · Public price list

Inquiry

Inquiry for Walker Tienkung.

Tell us the task and your country. We will reply by email with the next steps.

What are you interested in?
Robots you are interested in
We use your data to prepare the demo or offer, and pass the inquiry to the delivery partner, who prepares the offer and supplies the robots.

Thank you. Your inquiry is in.

We will reply by email with the next steps: a live demo where possible, and a written offer.

Rental in Slovenia

UBTECH · Legged (bipedal)

Walker S2

Industrial humanoid that swaps its own battery

Height
176 cm
Weight
70 kg
DoF
52
Humanoid robotsDetails
Rental in Slovenia

UBTECH · Wheeled base

Cruzr S2

Wheeled humanoid for industrial work

Payload
15 kg
Speed
2 m/s
Humanoid robotsDetails
Slovenia and Croatia only

AGIBOT · Four wheel omnidirectional chassis

G2

Industrial humanoid for precision assembly

Height
122.5 to 179.5 cm
Weight
185 kg
DoF
25
Humanoid robotsDetails

UBTECH · Legged (bipedal)

Walker C1

Service humanoid for reception and guided tours

Height
164 cm
Weight
55 kg
DoF
53
Humanoid robotsDetails
Slovenia and Croatia only

AGIBOT · Legged (bipedal)

A3 Ultra

Humanoid for long shifts

Height
174 cm
Weight
60 kg
DoF
51 to 71
Humanoid robotsDetails
Slovenia and Croatia only

AGIBOT · Legged (bipedal)

X2 Ultra

Compact humanoid for interacting with people

Height
131 cm
Weight
39 kg
DoF
30
Humanoid robotsDetails

Your inquiry

Your inquiry list is empty.

Add robots in the store, then send one inquiry for all of them.

Open the store

Price on request. No online payment. Nothing is ordered or paid here. We reply with a written offer.

Send inquiry Request a live demo