01
Full-size body
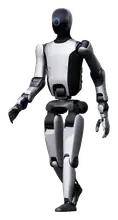
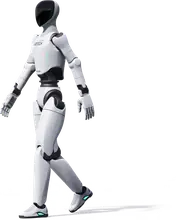
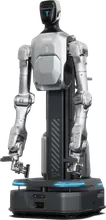
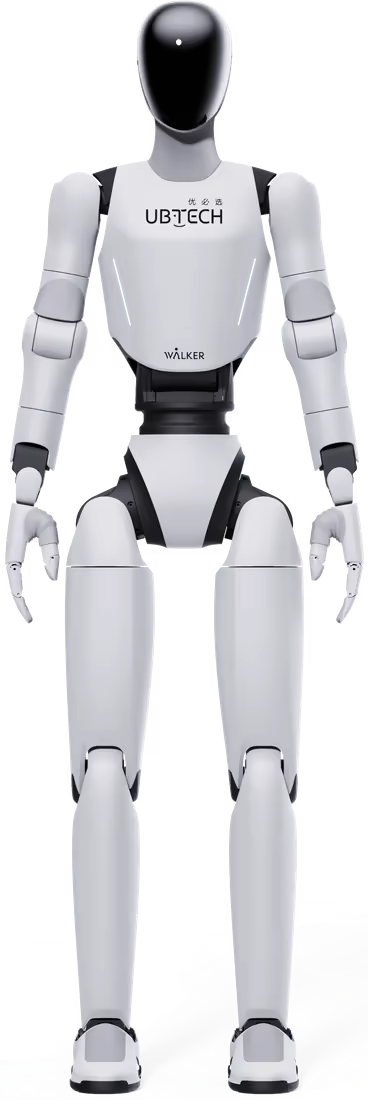
The robot is 164 cm tall and weighs 55 kg, with 53 degrees of freedom throughout the body for a natural posture. The exterior is designed for clothing, so you can dress the robot for a reception, a venue or a stage.
Store
Thirteen robots. Sales across the EU, rental in Slovenia.
All robots in the store Compare robots Rental in Slovenia Custom humanoid: free preorderUBTECH · Humanoid robots
Full-size service humanoid for reception, guided tours, events and teaching. It is 164 cm tall, has 53 degrees of freedom and can walk, run and dance.

Overview
Legged (bipedal)
Walker C1 is a full-size humanoid service robot for public and commercial spaces such as showrooms, museums, events and city services. Typical uses are multilingual reception and greeting, guided tours along routes set up in the cloud platform, shopping assistance, cultural performances and dance shows, patrolling and traffic assistance, and work in education and research. It converses through a large language model, can describe what it sees, and combines speech, gestures and facial expressions on a round display, including handshakes and greetings. It navigates using vision only, avoids obstacles and respects virtual walls set in the cloud platform, which also manages maps, tour scenarios, voices and logs. It steps out of its transport case by itself, is designed for setup by one person, and can be controlled with a remote control, a handheld console, a motion capture suit or VR glasses, with motions recordable as training data. A built in motion library, group dance synchronisation, an SDK and API in C++ and Python on ROS 2, and modular hands that accept third party grippers enable custom applications. Several features (offline conversation, custom personalities, VIP guest recognition, local LLM) are announced by the manufacturer for a later update.
Manufacturer footage


Images and video: manufacturer materials (UBTECH).
In motion
What it can do
The robot is 164 cm tall and weighs 55 kg, with 53 degrees of freedom throughout the body for a natural posture. The exterior is designed for clothing, so you can dress the robot for a reception, a venue or a stage.
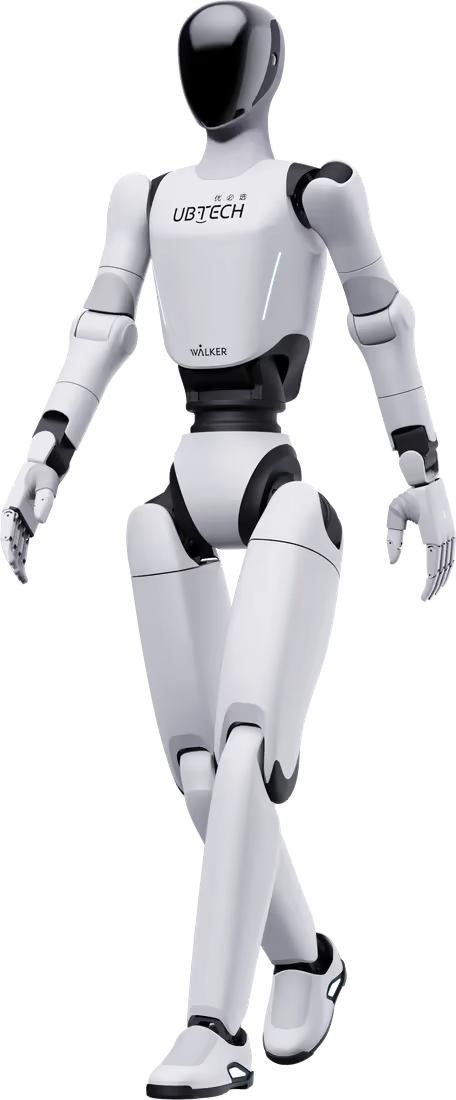
The robot moves at 3 m/s or more, and its walking and running resemble a human gait. Navigation builds a 3D map as it goes and plans a route around obstacles.
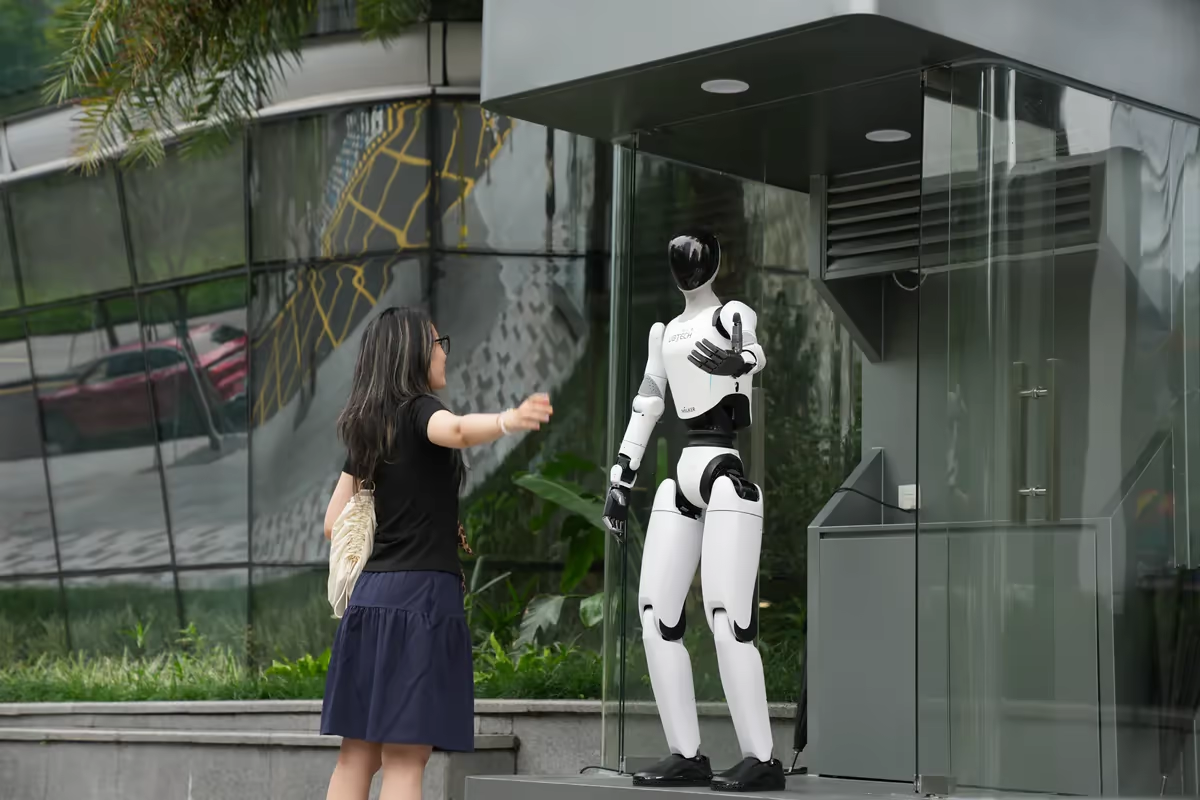
The robot is designed for multilingual reception, guided tours, shopping assistance and conversation with visitors at events. In education it works as a teaching assistant or a research platform.
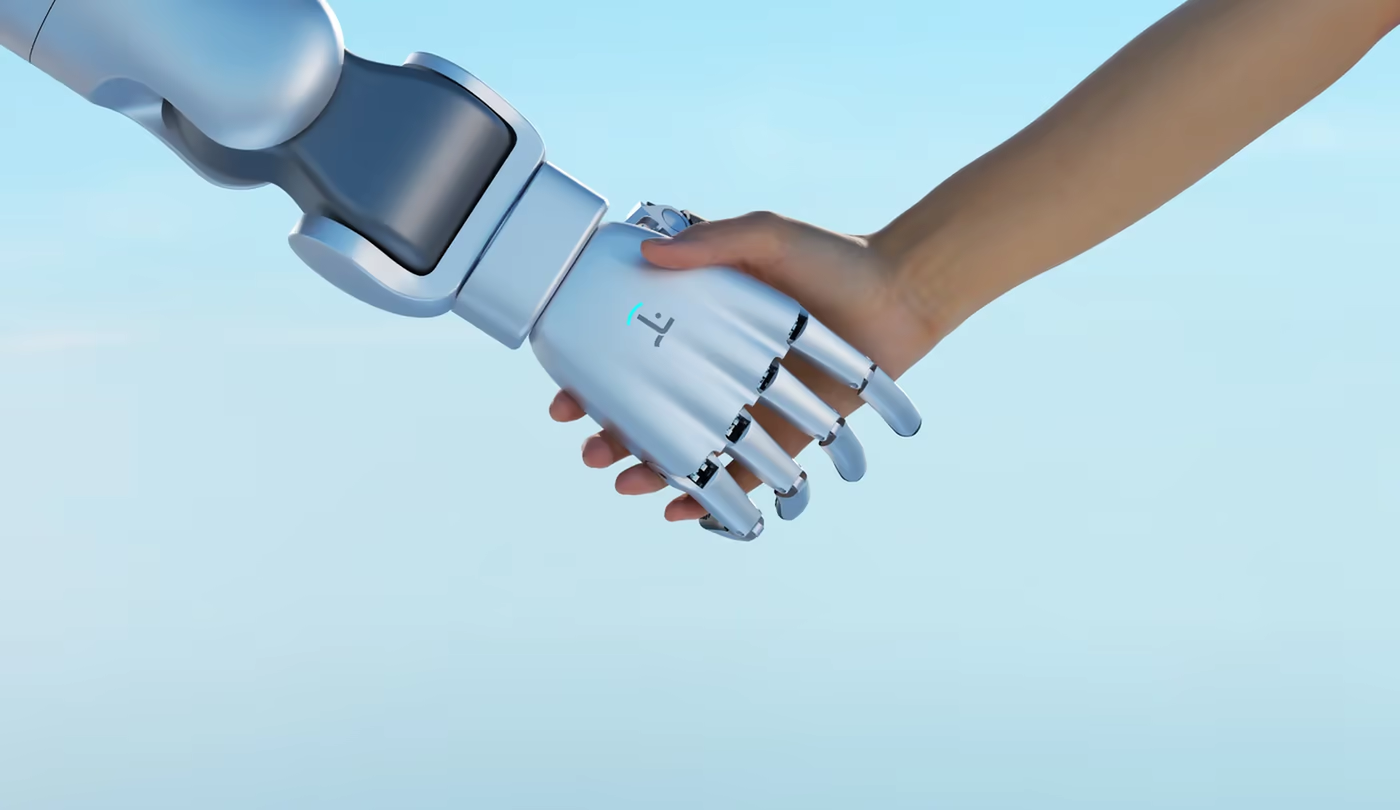
Dexterous hands are available as an option for both arms, and the joints use compliant force control.
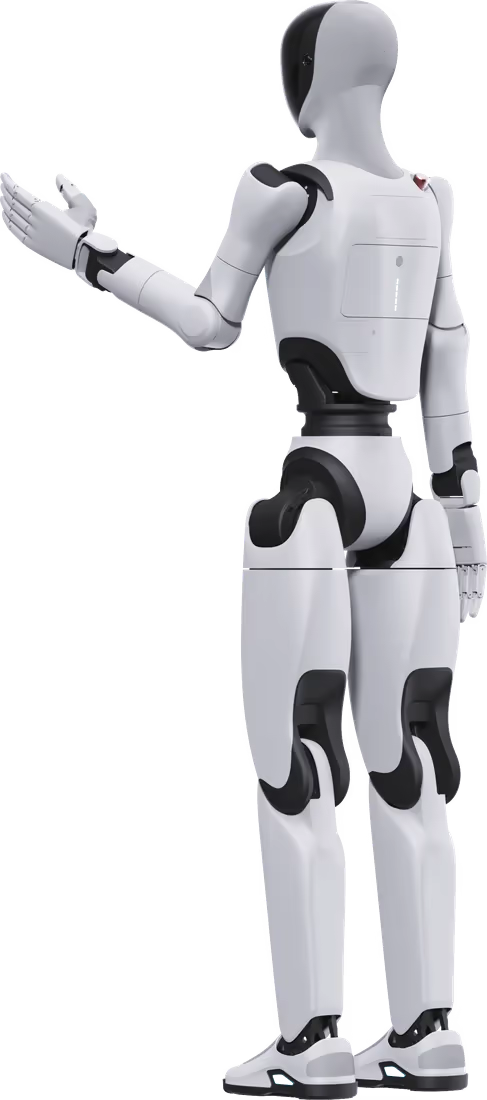
Language models run locally on the robot, and it can also connect to the cloud. A built in motion library, custom motions, standard interfaces and an SDK let you adapt it to your use.
The robot walks, runs and dances. It keeps its balance on one or both legs and also performs demanding dance moves, as in this rehearsal with dancers.
Walker C1 · Technical data
Variants
| Robot type | Full-size humanoid service robot |
|---|---|
| Operating system | Ubuntu + ROSA 2.0 |
| OTA updates | Supported |
| Operating environment | Indoors; outdoor use not recommended |
| Prohibited uses | Medical, military or other non-commercial scenarios; environments with flammable or explosive substances or strong electromagnetic interference |
| Boot time (from power button to remote control mode) | Approx. 2 to 3 minutes |
| Self unpacking time (until standing on the floor) | Approx. 20 seconds |
| Packing | Unpacking and packing with lift assistance supported; self packing announced for a future OTA update |
| Transport | C1 transport case |
| Specification | Model hands (standard) | Dexterous hands (optional) |
|---|---|---|
| Height | 164 cm | |
| Arm span (without dexterous hands) | 1280 mm | |
| Weight with model hands | Approx. 55 kg | On request |
| Weight with dexterous hands | On request | Approx. 56 kg |
| Specification | Dexterous hands (optional) |
|---|---|
| Total degrees of freedom | 53 (31 in the body, 22 in the dexterous hands, including passive) |
| Legs | 6 degrees of freedom each |
| Waist | 3 degrees of freedom |
| Arms (without dexterous hand) | 7 degrees of freedom each |
| Head | 2 degrees of freedom |
| Dexterous hand (optional) | 11 degrees of freedom per hand (6 active + 5 passive) |
| Dexterous hands | 2 (optional) |
| Payload (without dexterous hands) | One arm: 3 kg; both arms: 6 kg |
| Recommended continuous dancing | ≤ 10 minutes |
| Built in dances | Two dances, each longer than 30 seconds; can be performed on thin carpets, marble and epoxy floors |
| Group performance | Group control with centimetre accurate synchronisation and low latency command distribution |
| Hand configurations | Standard: model hands (removable, compatible with third party dexterous hands/grippers). Optional: UBT third generation dexterous hand, Lite version |
| Third party end effectors | Third party two finger grippers and wrist cameras supported, controlled via teleoperation |
| Total battery runtime | 2.5 to 3 hours |
|---|---|
| Max. endurance (walking on the spot, 100 % to 0 %) | ≥ 3 h |
| Typical endurance (dancing, 100 % to 0 %) | ≥ 2 h |
| Charging time (0 % to 100 %) | Approx. 90 minutes |
| Rated voltage | 48 V DC / 8 A |
| Charging | 52 V DC / max. 14 A |
| Battery | Swappable (battery C0445D5 included) |
| Charging methods | Charge the robot directly with the power adapter, or remove the battery and charge it separately with the direct battery charging cable |
| Mains power for charging | Grounded socket 100 to 240 V / 50 to 60 Hz; ambient 0 to 40 °C |
| Long term storage (unused for more than 1 month) | Robot: switched off, battery removed, dry ventilated room at 0 to 30 °C. Battery: stored separately at 0 to 25 °C, humidity 30 % to 60 %, checked monthly, charge level 50 % to 80 % |
| Compute unit | Onboard NVIDIA Jetson Thor 128 GB, 2,070 TFLOPS (FP4 sparse) |
|---|---|
| Fisheye cameras | 2 |
| Binocular (stereo) camera | 1 |
| Monocular camera | 1 |
| High precision inertial measurement unit (IMU) | 2 |
| Navigation | Vision only U-SLAM navigation, spatial perception, active obstacle avoidance and detour; virtual walls |
| Camera views in teleoperation | Five camera angles |
| Display | 2.8 inch round interactive display |
|---|---|
| LCD display | 1 |
| Display response time / max. brightness | < 100 ms / > 800 nits |
| Microphones | 4 |
| Speakers | 2 |
| Indicators | Battery status LED indicators |
| Controls | Emergency stop button and power switch |
| Emergency stop | The emergency stop button on the robot's back locks all motors; servo emergency stop cable for professional use |
| Languages | Chinese and English (mixed use supported; dialects not supported) |
| Wake word | "Walker Walker" |
| Online conversation latency | < 2 seconds end to end (good network) |
| Conversation distance | At least 1.5 m; up to 5 m with a wireless microphone |
| Voices | Male, female, child |
| Large model | Alibaba Bailian platform ("omni" multimodal model); cloud and local operation supported |
| Connectivity | Global 4G/5G connectivity; optional plug in 5G module |
| Remote control | Remote control included (movement in six directions, walk/task/mode switching, emergency stop); optional handheld console (joystick + touchscreen app) |
| Teleoperation devices | Motion capture suit (Xsens + Manus gloves) and VR (Pico); full body and half body |
| SDK and API | Available (motion control, arm control, sensor access, navigation, telemetry, system configuration, diagnostics) |
|---|---|
| Programming languages | C++ and Python |
| Development environment | ROS 2 container on the robot: Ubuntu 22.04 + ROS 2 Humble; ROS2 with URDF supported; Mac and Windows not supported |
| Recommended robot version for the SDK | Main version 0.0.6 or later |
| SDK demo programs | Audio playback, power board and battery status, arm, dexterous hand and head control, arm and robot status, camera subscription |
| Own large language model | A customer model can be used if deployed in the cloud or at the network edge |
| Operating temperature | 3 °C to 40 °C |
|---|---|
| Relative humidity | 30 % to 80 % (non condensing) |
| Storage temperature | -10 °C to 50 °C |
| Minimum working area | One robot: at least 4 m² (2 m × 2 m); shared aisle width ≥ 1.5 m |
| Floor | Level, flatness deviation ≤ 5 mm/m²; load capacity ≥ 150 kg/m² |
| Lighting | Working area illuminance ≥ 200 lux |
| Network (online use) | Gigabit Ethernet recommended, latency ≤ 100 ms, packet loss ≤ 1 % |
| Safety distance during operation | ≥ 1.5 m |
Walker C1 · Images
Buy and rent
Price on request. Sales across the EU, on inquiry. Available in Slovenia, Croatia, Serbia, Bosnia and Herzegovina and North Macedonia. Other countries: on request.
Price on request. You receive a written offer with contract terms, prepared for your configuration, software and service.
Rental is offered in Slovenia for Walker S2 and Cruzr S2. This model cannot be rented: see it at a live demo or request an offer.
Coming soonOnline payment · Public price list
Inquiry
Tell us the task and your country. We will reply by email with the next steps.
We will reply by email with the next steps: a live demo where possible, and a written offer.
Preview: this entry is saved only in your browser and has not been sent.

Industrial humanoid that swaps its own battery

Wheeled humanoid for industrial work

Industrial humanoid for precision assembly

Humanoid for long shifts

Compact humanoid for interacting with people

Humanoid platform for research and teaching